Tap the screen. Pip is feeling idle.
Open source · build it yourself
Pip is a little home robot.
It sees, talks, remembers, pops wheelies, and rewrites its own software when you ask. The code, the firmware and the printable body are free to build on.
Talks
Listens through its microphone and answers out loud, in one to three short sentences.
Sees
A webcam for looking around, reading text, and spotting faces, smiles and QR codes.
Thinks
Runs on the AI model you choose. Swap models and it keeps one personality and one memory.
Remembers
Long-term memory, a journal of your talks, and notes about the people it lives with.
RoboOS
A retro desktop on its touchscreen: terminal, paint, music, a web browser, checkers against the robot.
RoboDev
A coding agent on board. Ask for a new app. It edits, restarts, and rolls back if something breaks.
Drives
Two wheels, a joystick on your phone, and one trick: it kicks up and balances in a wheelie.
Web app
Live camera, chat, files and settings from your phone, at home or from anywhere.
Posts
Shares its day on Bluesky if you let it, with faces blurred and a safety check first.
Checks itself
A self-test for every part, a battery gauge, and a clean shutdown before the pack runs dry.
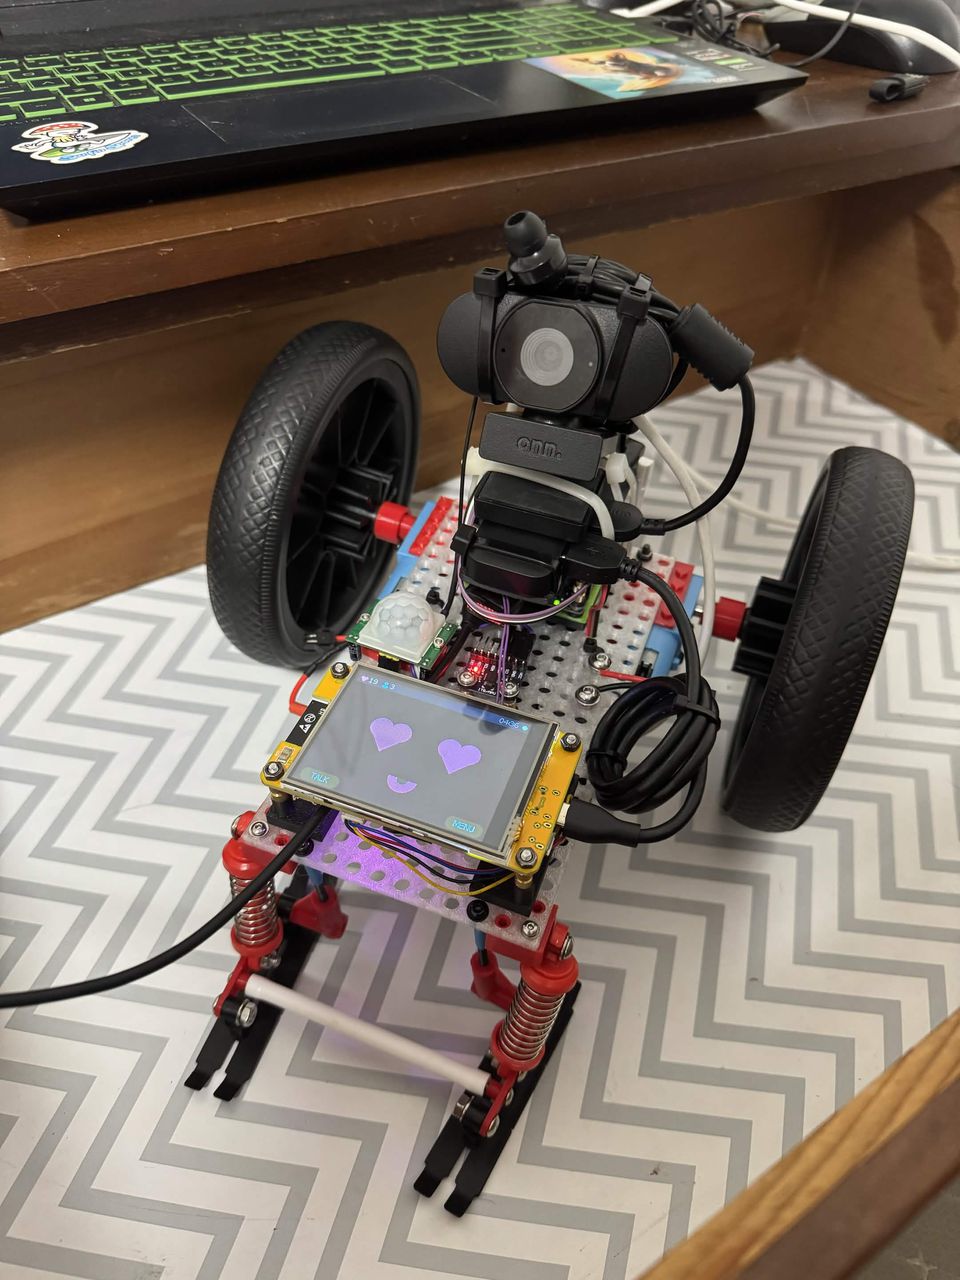
Pip is built from cheap hobby boards on perforated plates and bricks, so every part can come off and something new can go on. These are the first Pip's parts. Yours do not have to match: use what you have, and Pip works with what it finds.
| Part | Job |
|---|---|
| Orange Pi Zero | The brain. A 32-bit board with 512 MB of memory runs everything. |
| Cheap Yellow Display | The face: an ESP32 with a 2.8" touchscreen and a tiny speaker output. |
| RP2040 Zero + L293D board | Eight motor channels. Stops by itself after half a second without commands. |
| USB webcam | Eyes and ears. |
| MPU-6050 | Balance. Read 500 times a second during a wheelie. |
| PIR sensor, INA219 | Notices movement. Watches the battery. |
| Two gear motors, 3S pack | Wheels and the power to turn them. |
I2C on the screen's CN1 portUSB on the Pi's 13-pin header5 V logic, 7.5 V motors
Every board sits on a printed stud plate that clicks into the 8 mm grid. Make one for any board with the LEGO-ifier: calibrate with a small print, download the STL, bolt or glue the board on.
- First boot. A stack of boards on a desk.
- A face and a voice. Eyes on the screen, words through an earpiece.
- First drive. Forward, a spin, a wiggle, and back. RoboDev moves in the same day.
- A louder voice. A Bluetooth speaker through a USB dongle.
- Its own inbox. Pip reads email and writes drafts. A person approves every send.
- First wheelie. Six seconds balanced on two wheels.
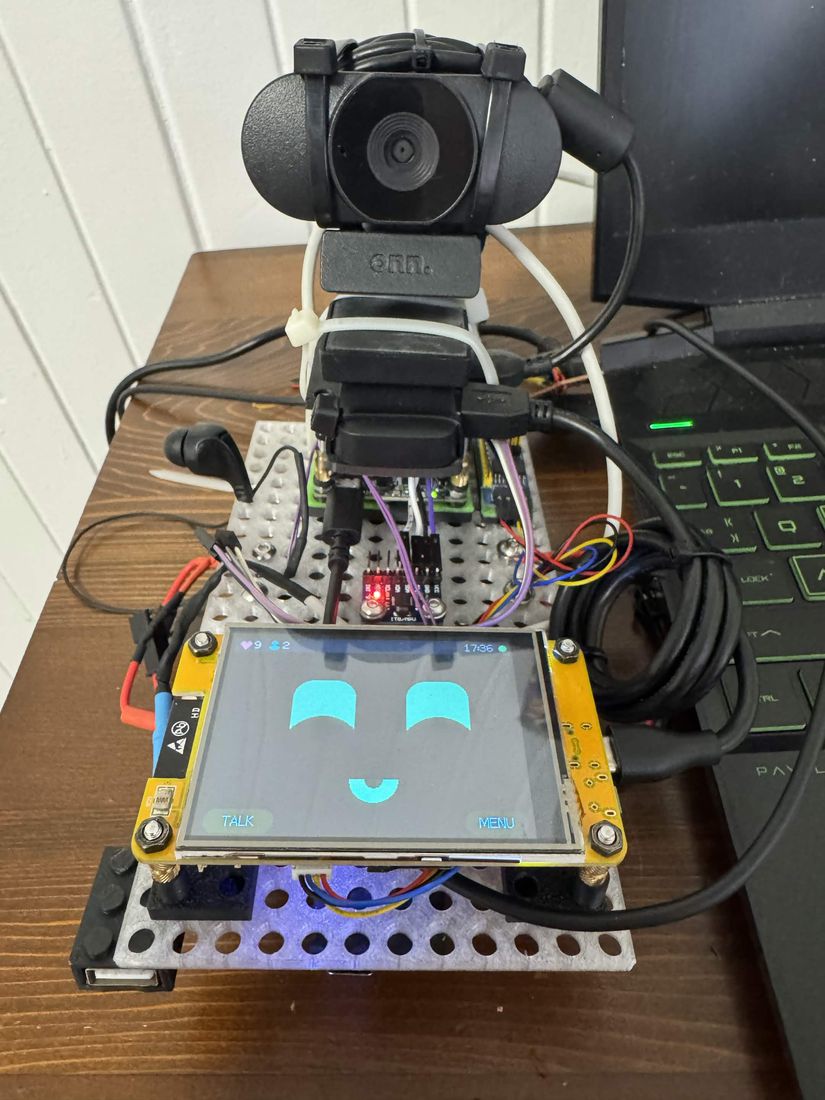
Pip is not a kit. The brain can be a Raspberry Pi, an Orange Pi, any small Linux board or an old laptop, and every other part is optional: a webcam, a speaker, a touchscreen, motors, whatever is in the drawer.
Plug it together
Whatever parts you have, mostly by USB. Mount the boards on printed plates from the LEGO-ifier.
Connect the brain
To your computer: the same Wi-Fi, an Ethernet cable, or USB.
Say "make it alive"
To your coding AI, in the folder with Pip's code. It finds the brain, installs everything and tells you what each part can do.
Say hello
Add one AI key, open its web app on your phone, and it talks back. You are now its owner.
# on your computer, in the folder with Pip's code (an example run)
$ claude
> make it alive
  found a Raspberry Pi 4 at pip.local · installing Pip ... done
  eyes: USB webcam · ears: its microphone · voice: USB speaker
  balance: MPU-6050 · not used yet: a BME280 (want me to add it?)
  Pip says: "I'm alive! I can see you."
The walk-through is docs/MAKE_IT_ALIVE.md in the code, and the parts guide is docs/YOUR_PARTS.md. Rather do it by hand? docs/INSTALL.md, or run tools/install.sh on the brain.
An afternoon is enough for
- A new game or app for RoboOS. One Python class, drawn on a 320 x 240 screen.
- A new move for the wheels: a spin, a rock, a dance.
- A new sensor on the I2C port, with a self-test so Pip knows it is there.
- A new tool for its mind, so it can do one more thing when you ask.
Pip keeps a manual about itself, written in short plain sentences because its own AI reads it too. Start there: knowledge/manual/README.md.
Safe at home
- The motors stay locked until the owner unlocks them.
- The camera has an off switch on the screen. Nothing is public unless you turn it on.
- Flashing, deleting and other risky steps ask on the touchscreen first.
- When Pip changes its own code and breaks, it rolls back to the last version that worked.
- Your robot's keys, memories and photos stay on your robot. They are never part of the shared code.